Jonathan Setiawan

Hi! I'm a tech geek and I love robots

View Projects

About Me

Hi! I'm Jonathan, a student majoring in Information Systems Science and Engineering at Ritsumeikan University.

I enjoy challenging myself in robotics, SciML, and computer vision related fields.
Love reading books, working out, and watching anime in my spare time.
Open to discussing collaborative research or projects in robotics or SciML.

Tech Stack & Tools

Programming Languages

Python Python JavaScript JavaScript TypeScript TypeScript Java Java C++ C++ Dart Dart MIPS Assembly

Mobile & Web Development

React React / Native Expo Expo Flutter Flutter Next.js Next.js HTML5 HTML5 CSS3 CSS3 Tailwind CSS Tailwind CSS Three.js Three.js Angular Angular

Machine Learning & AI

TensorFlow TensorFlow PyTorch PyTorch OpenCV OpenCV YOLO Keras Keras Scikit-learn Scikit-learn Jupyter Jupyter NumPy NumPy Pandas Pandas Genkit Gymnasium PettingZoo OpenCLIP NetworkX

Robotics & Simulation
ROS/ROS2 ROS / ROS2 Gazebo Gazebo RViz MoveIt Ubuntu Ubuntu

Backend, Database & DevOps

Node.js Node.js Express Express.js Spring Boot Spring Boot Flask Flask FastAPI FastAPI Firebase Firebase SQLite SQLite MySQL MySQL Docker Docker Netlify Netlify GitHub Actions Actions

Tools & Others

Git Git GitHub GitHub Android Studio Android Studio Figma Figma Ren'Py Make Ruff uv

Featured Projects

Research & Robotics

Robotics

Foveated Teleoperation Task-based Study

A Unity-based teleoperation system for Pioneer robots featuring gaze-contingent foveated streaming to optimize perceptual quality and bandwidth.

UnityRobotics
AI

EFT-VPR

Event Forecasting Transformer improving Recall@1 by 13.8% via 8-head autoregressive modeling and InfoNCE contrastive learning.

AITransformer
Signal Processing

AESP

Numba-accelerated Poisson filtering delivering +13.82 dB SNR gain and 37.8% bandwidth reduction for event-stream signal processing.

PythonNumba
NLP

Scientific Abstract Classifier (SciBERT-CTFT)

SciBERT + SetFit classification pipeline strengthened with context-injection augmentation for more robust scientific abstract categorization.

AINLP
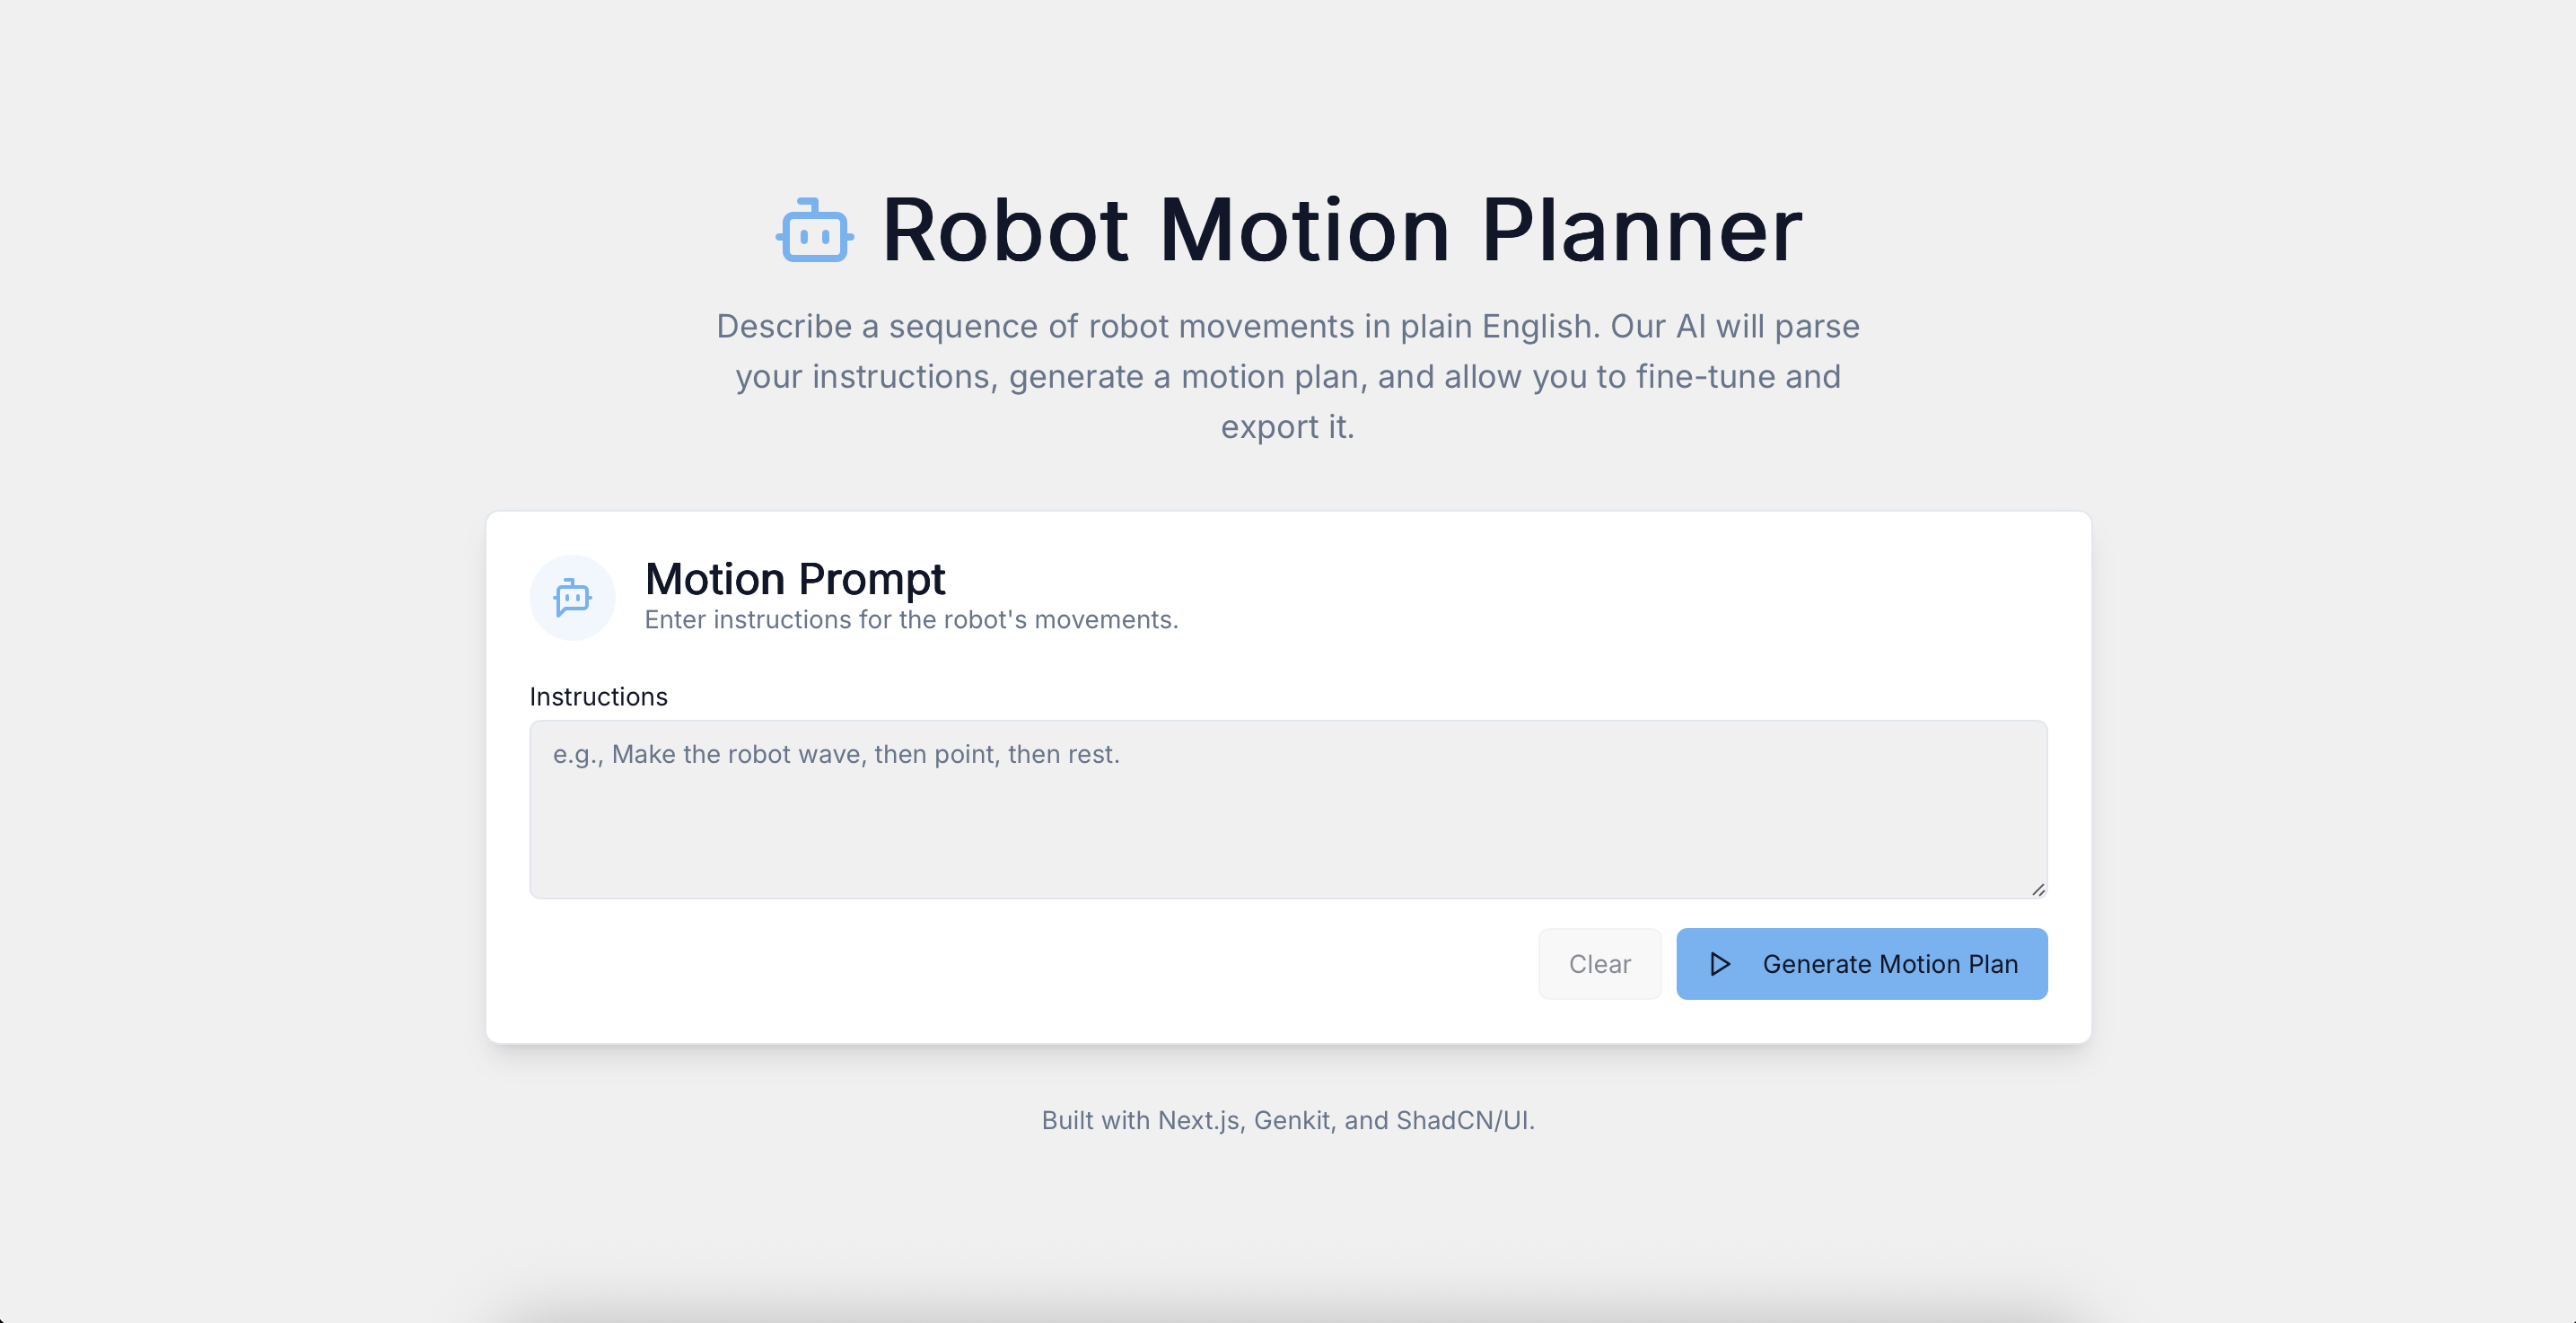
Robot Motion Planner

Robot Motion Planner

Translated natural-language robotic intents into MoveIt trajectories for reliable 6-DOF planning and execution workflows.

TypeScriptRobotics

Full-Stack & Systems Engineering

Backend

ergo-api

Built a zero-trust Go API gateway with real-time anomaly detection, OPA policy enforcement, and JWT identity validation for hardened service access.

GoSecurity
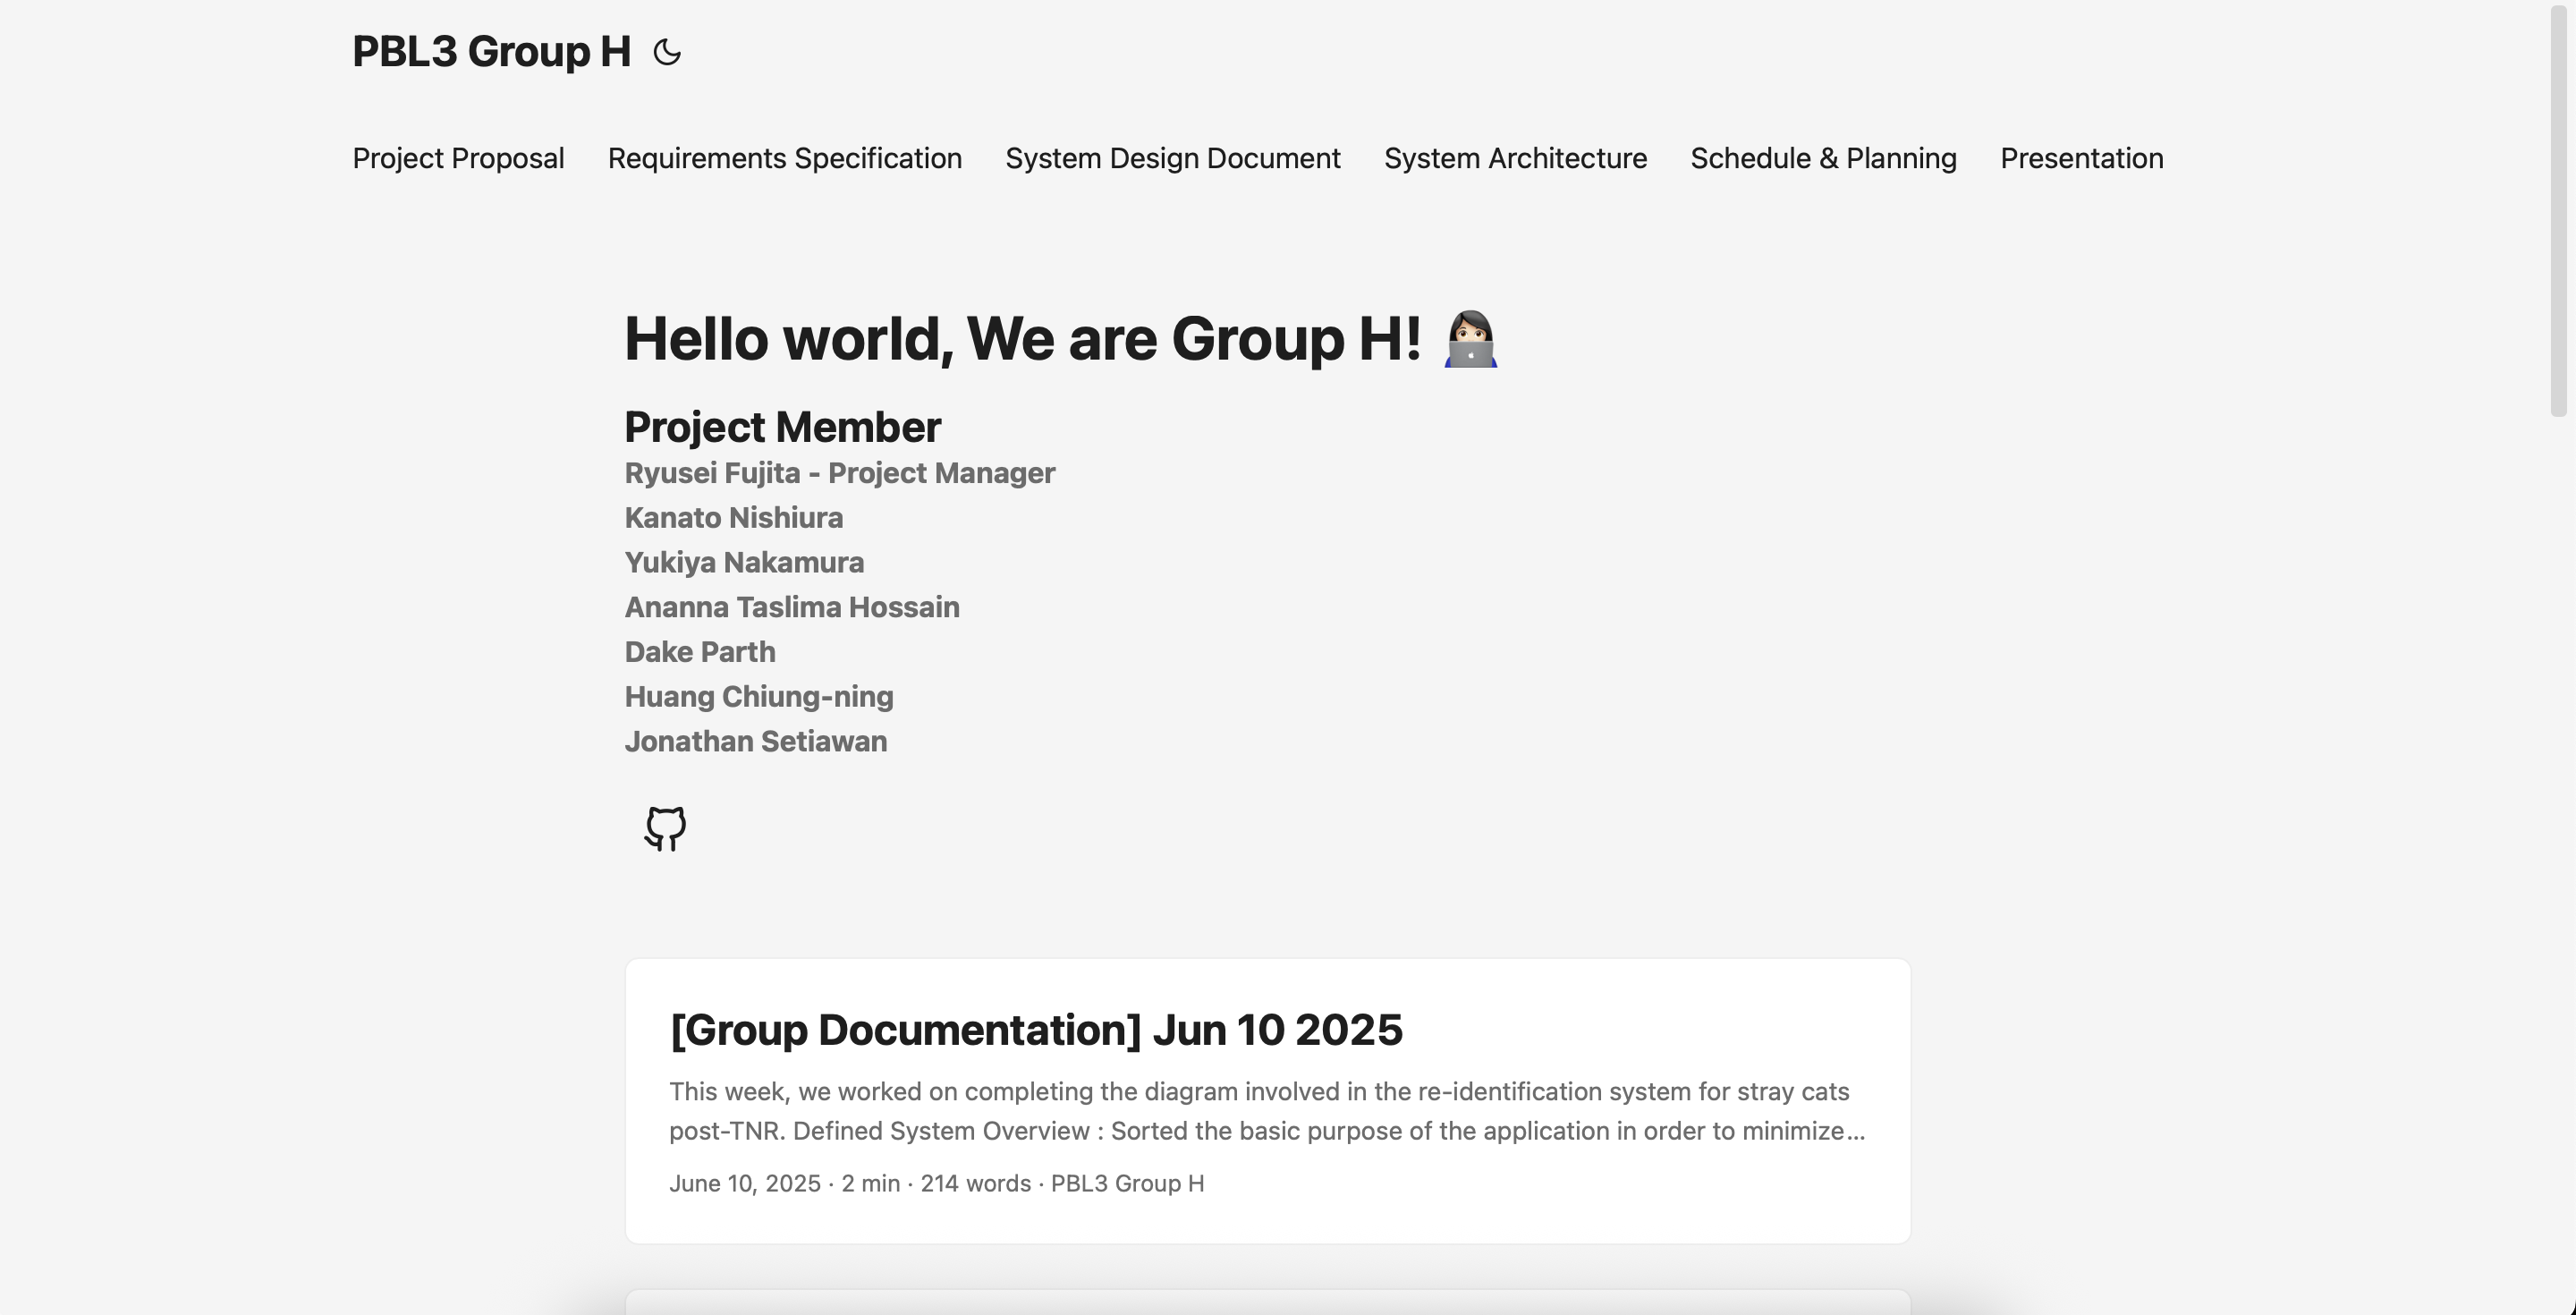
Smart Re-Identification System for Stray Cats

Smart Re-Identification System for Stray Cats (Post-TNR)

Delivered a React Native + Siamese re-identification platform to reduce redundant treatments through repeat-cat matching in field operations.

React NativeAI

Education

Ritsumeikan University (立命館大学)

Osaka, Japan

Graduation Date: Mar 2028
  • College of Information Systems Science and Engineering
  • GPA: 4.45/5.0
  • Relevant Coursework: Network systems, Artificial Intelligence, Project Based Learning, C Programming, DSA

Research & Leadership Experience

FPTジャパン株式会社

Tokyo, Japan

May 2026 - Aug 2026
  • Physical AI Team Robot Learning Engineer
  • Trained and evaluated imitation-learning policies (ACT, Diffusion Policy variants, SmolVLA) on the LeRobot framework, including MolmoAct for grounded trajectory planning from 2.5D visual input
  • Built simulation environments for robot arm manipulation in MuJoCo, Gazebo, and NVIDIA Isaac Sim, and ran sim-to-real transfer of learned policies onto physical hardware

iCOM技研株式会社

Hyogo, Japan

Jul 2025 - Present
  • Robotics ML Engineer
  • Developed the perception stack for robotic parcel picking: trained and evaluated RGB-D fusion models and point cloud segmentation models to detect suctionable top surfaces on unknown parcels
  • Developed a pipeline for class-agnostic segmentation with synthetic RGB-D training using BlenderProc domain randomization to generalize to unseen parcel types
  • Architected the end-to-end palletizing/depalletizing system for UR5e, UR10e, and UR20 robots

Ritsumeikan University (立命館大学)

Osaka, Japan

Jul 2024 - Present
  • RiOne (Robocup @Home League) Robotics Club Computer Vision Team Lead
  • Architected a multi-node ROS 2 Humble perception stack and sensor-fused navigation on TurtleBot3 WafflePi with face re-identification and temporal tracking for persistent HRI and autonomous obstacle avoidance.
  • Engineered a self-improving object recognition pipeline and achieved 3rd Place for Open Challenge and Best Poster Award in RoboCup Japan Open 2026 (Bridge Division).

Awards & Qualifications

村井シークス奨学金 (Murai SIIX Scholarship)

Ritsumeikan University / Murai SIIX Foundation

Apr 2025 – Mar 2027
  • Awarded for academic achievement, innovation potential, and contributions to international exchange in engineering fields.

JASSO Monbukagakusho Honors Scholarship

Japan Student Services Organization

Apr 2024 – Mar 2025
  • Awarded for strong academic performance and leadership as an international student in Japan.

International English Language Testing System (IELTS)

Overall Band Score

Oct 2022
  • Overall Band Score: 8.0

University of Waterloo Cayley Mathematics Competition

Vancouver, Canada

2021
  • Distinction Award for High-school oriented mathematics competition

Get In Touch

Send me a message

Let's connect!

I'm always interested in new opportunities and exciting projects. Whether you want to collaborate, have a question, or just want to say hi, feel free to reach out!